In this article
In a decentralized federation, a node may be technically connected and still be a poor collaborator. Its model can drift, its position can become inconsistent with the mission or its traffic pattern can indicate a compromised process. The Flighter study explores a practical response: treat situational awareness as a reliability signal that helps the federation decide how much influence a peer should receive.
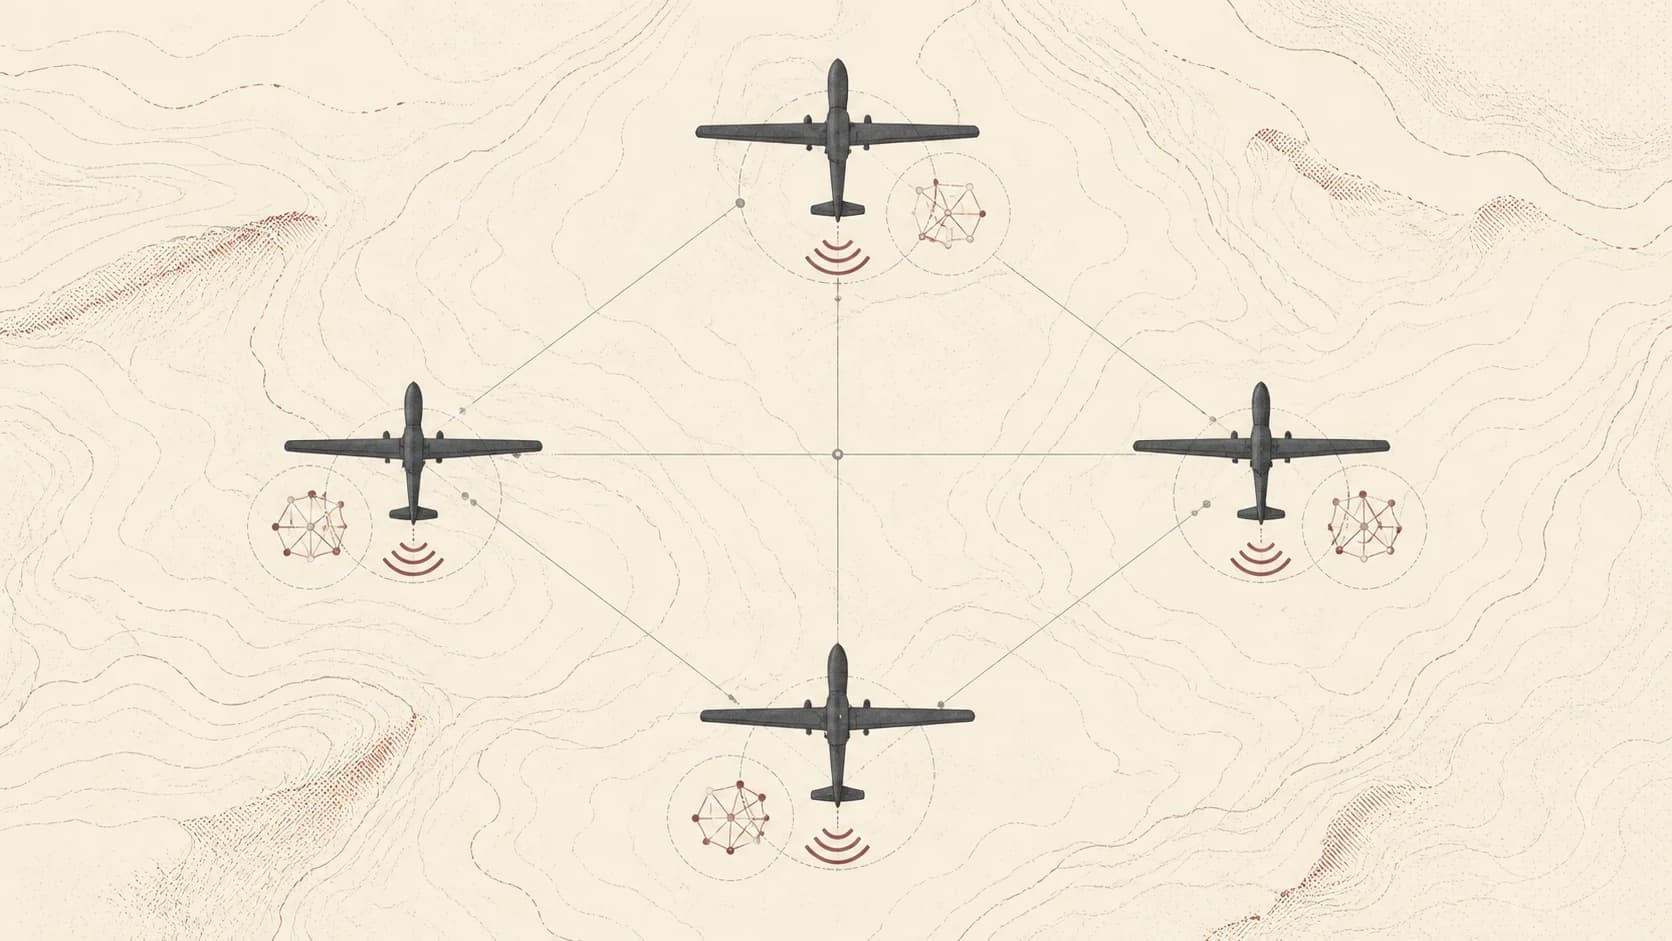
The scenario is deliberately demanding. Four aircraft equipped with synthetic-aperture radar collaborate on aerial reconnaissance while their formation, positions, resources and links can change. The learning model uses VGG16 and the evaluation combines MSTAR, SAMPLE and OpenSARShip. The point is not to claim that one score solves adversarial learning. It is to show how operational context can be connected to decentralized model exchange.
Why model similarity is not enough
Suppose a peer sends an update that looks statistically plausible. A conventional aggregation rule may give it weight because it is close to the other models. That signal can be useful, but it cannot answer several operational questions:
- Is the platform still in the expected formation?
- Is its geoposition consistent with the mission?
- Has its communication rate changed suddenly?
- Is it consuming resources in an unusual way?
- Do its local predictions agree with the rest of the team?
Situational awareness adds these questions to the trust decision. It does not replace validation of the update, and it should not be interpreted as proof that a node is benign.
From context to bounded influence
The mechanism can be understood as a pipeline:
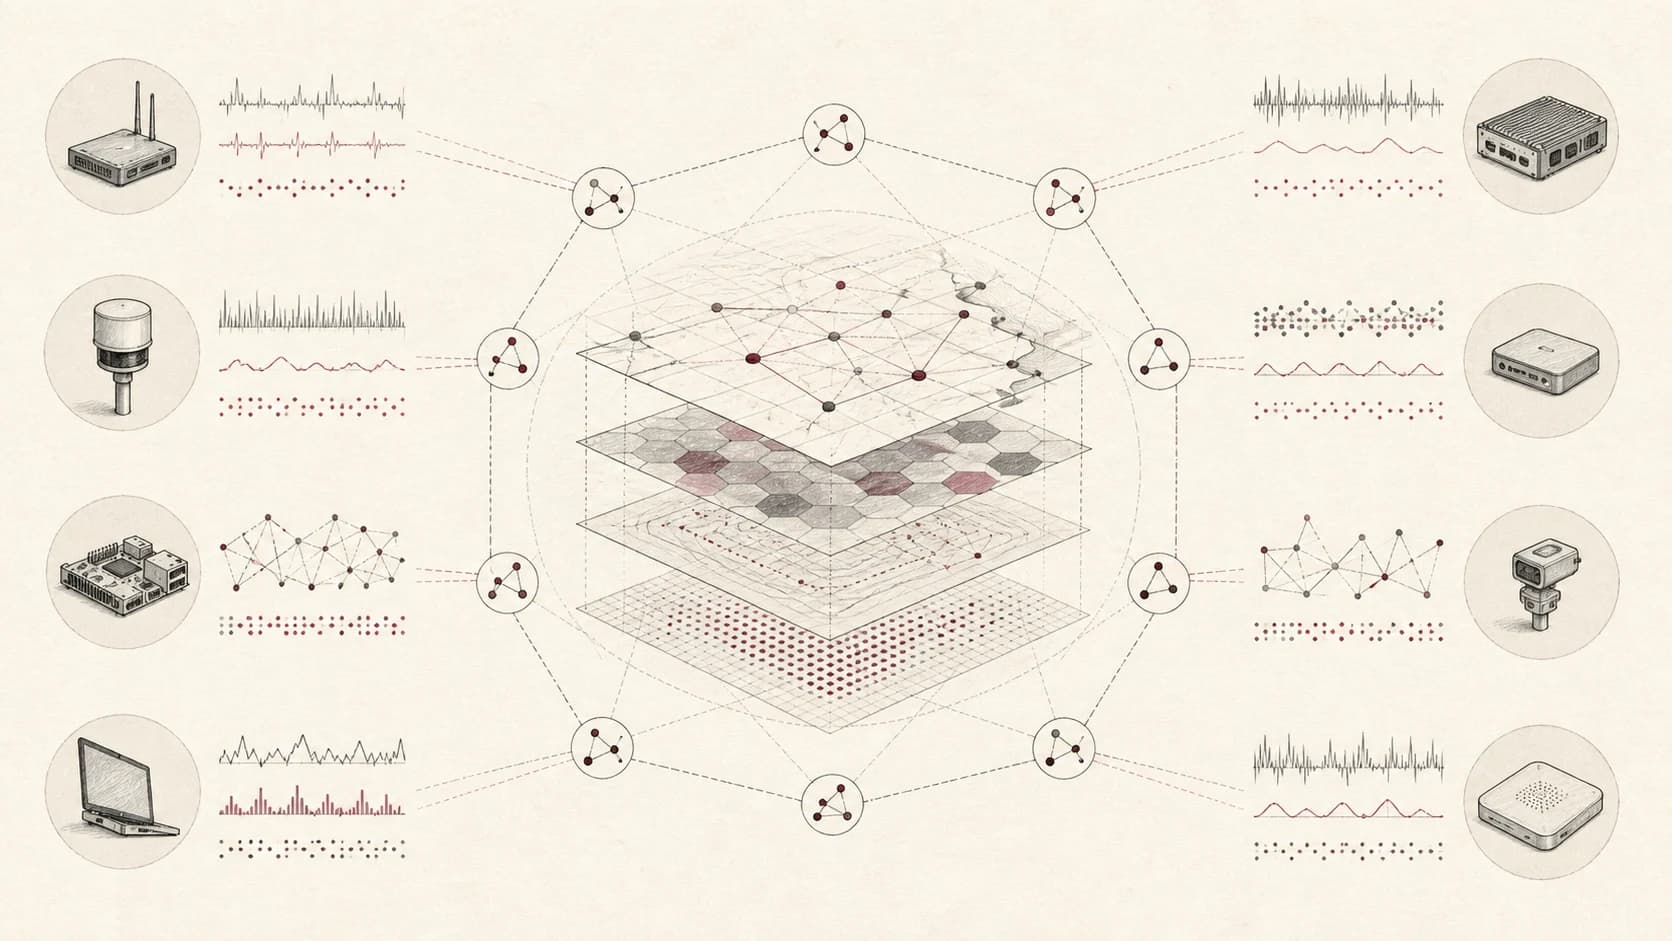
- Each participant collects local model and operational indicators.
- The indicators are normalized so that different units can be compared.
- A weighted score summarizes the current reliability evidence.
- The score is compared with a threshold that can change with the operating context.
- The contribution is accepted with full, reduced or zero influence according to the policy.
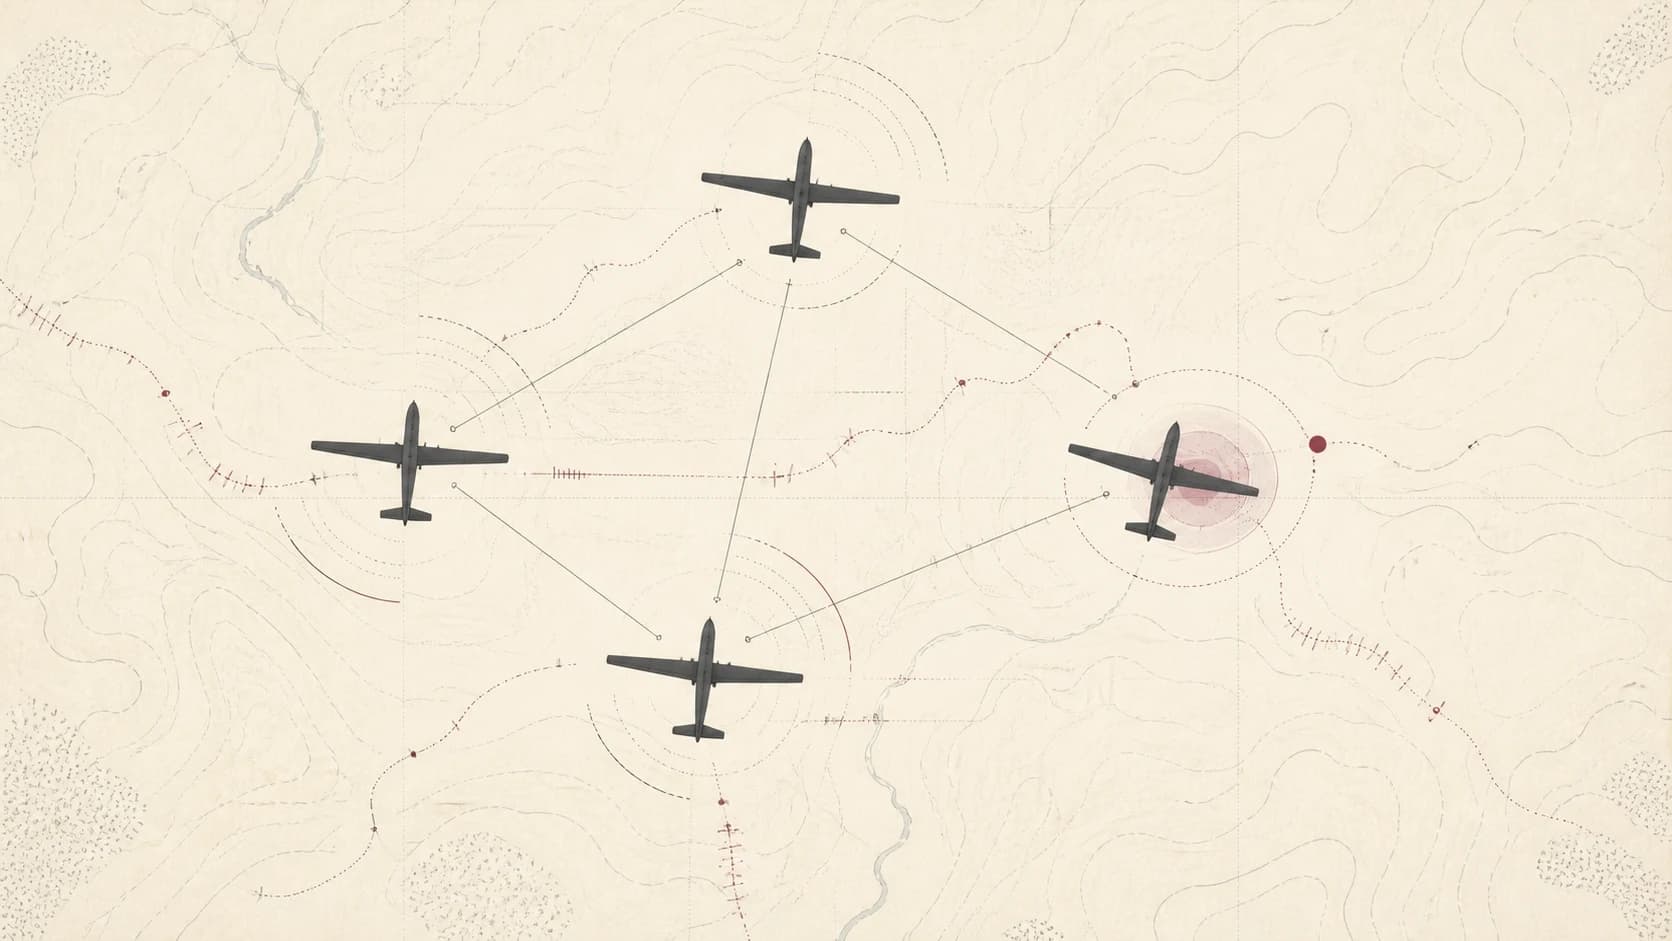
An illustrative score is:
If the formula does not fit, focus it and use the left and right arrows, or scroll horizontally.where are normalized signals for peer and expresses their relative importance. A threshold policy can then define:
If the formula does not fit, focus it and use the left and right arrows, or scroll horizontally.with increasing the influence of reliable peers and reducing it when the evidence is weak. The function must be bounded. If a peer remains below the policy threshold, the network can limit its connections or require a recovery procedure instead of allowing unlimited influence.
What the scenario teaches
The value of the approach is architectural. A model update is interpreted together with the circumstances under which it was produced. A sudden position deviation and an unusual traffic burst may not prove an attack, but they can justify a lower aggregation weight while an operator or a recovery policy investigates.
This also exposes an important design trade-off. More context can improve detection of abnormal behavior, but it increases the amount of metadata that has to be collected and protected. The indicators should therefore be chosen for a concrete threat model, normalized consistently and tested under missing or manipulated observations.
What the experiments do and do not show
In the Flighter evaluation, the defense module is studied under a controlled simulated reconnaissance mission. It reports useful behavior under position manipulation, collision-course scenarios and poisoning, but the results should be read as evidence for the tested configuration, not as a universal guarantee for every aircraft, sensor or network.
The study also keeps a baseline without the situational-awareness defense component. This comparison matters because a robustness mechanism can introduce overhead or change convergence. The engineering question is not simply whether the extra score detects a bad peer. It is whether the improvement is worth the computation, communication and operational complexity in the target environment.
A deployment-oriented checklist
Before using situational awareness in a DFL protocol, define:
- the indicators that are actually observable at each node,
- the normalization and time window for every indicator,
- how missing or delayed context is represented,
- who can change the weights and threshold,
- the maximum influence of one peer,
- the audit trail for a reduced or revoked contribution,
- the recovery path for a node that becomes unreliable.
The broader lesson is that robustness is a cross-layer property. Model validation, network behavior and mission context should inform one another without collapsing into a single opaque trust score. Flighter offers a concrete research pattern for doing that in a decentralized federation.
Isolate the value of each indicator
To extend the study, I propose an ablation comparing model signals, operational context and their combination. Keep the attack, graph and training budget fixed. If each configuration also changes participation policy, the difference cannot be attributed to context.
The primary reference is Flighter, IEEE Communications Magazine. This note's equations are explanatory abstractions rather than replacements for the paper's algorithm and parameters. A follow-up experiment becomes new evidence only after it has been run.
Missing context, false context and recovery
An unavailable position should not be encoded as an impossible position. Represent availability and age for every indicator. Compare complete, omitted and altered signals. This distinguishes resistance to missing data from resistance to manipulation.
When reducing participant influence, retain previous and resulting weights. If weights are renormalized, record the accepted set and the behavior when it is empty. A threshold without that policy leaves aggregation underspecified.
A recovery test introduces a legitimate participant whose anomalous behavior ends. Measure time to regain influence and quality alongside false rejection. Avoid making historical penalties prevent rejoining indefinitely: reputation should describe recent evidence rather than become a permanent label.
The adversarial metrics guide explains comparison across these conditions. The situational awareness note connects the result to an operational view.